Cooperative Robots
S-Eco
Ecotronic collaborative robots are widely used in automobile manufacturing, electronic assembly, household appliances, new energy, new materials, semiconductors, metal processing, bio-medicine, aerospace, food chemical industry, logistics handling, general equipment and other industrial fields.
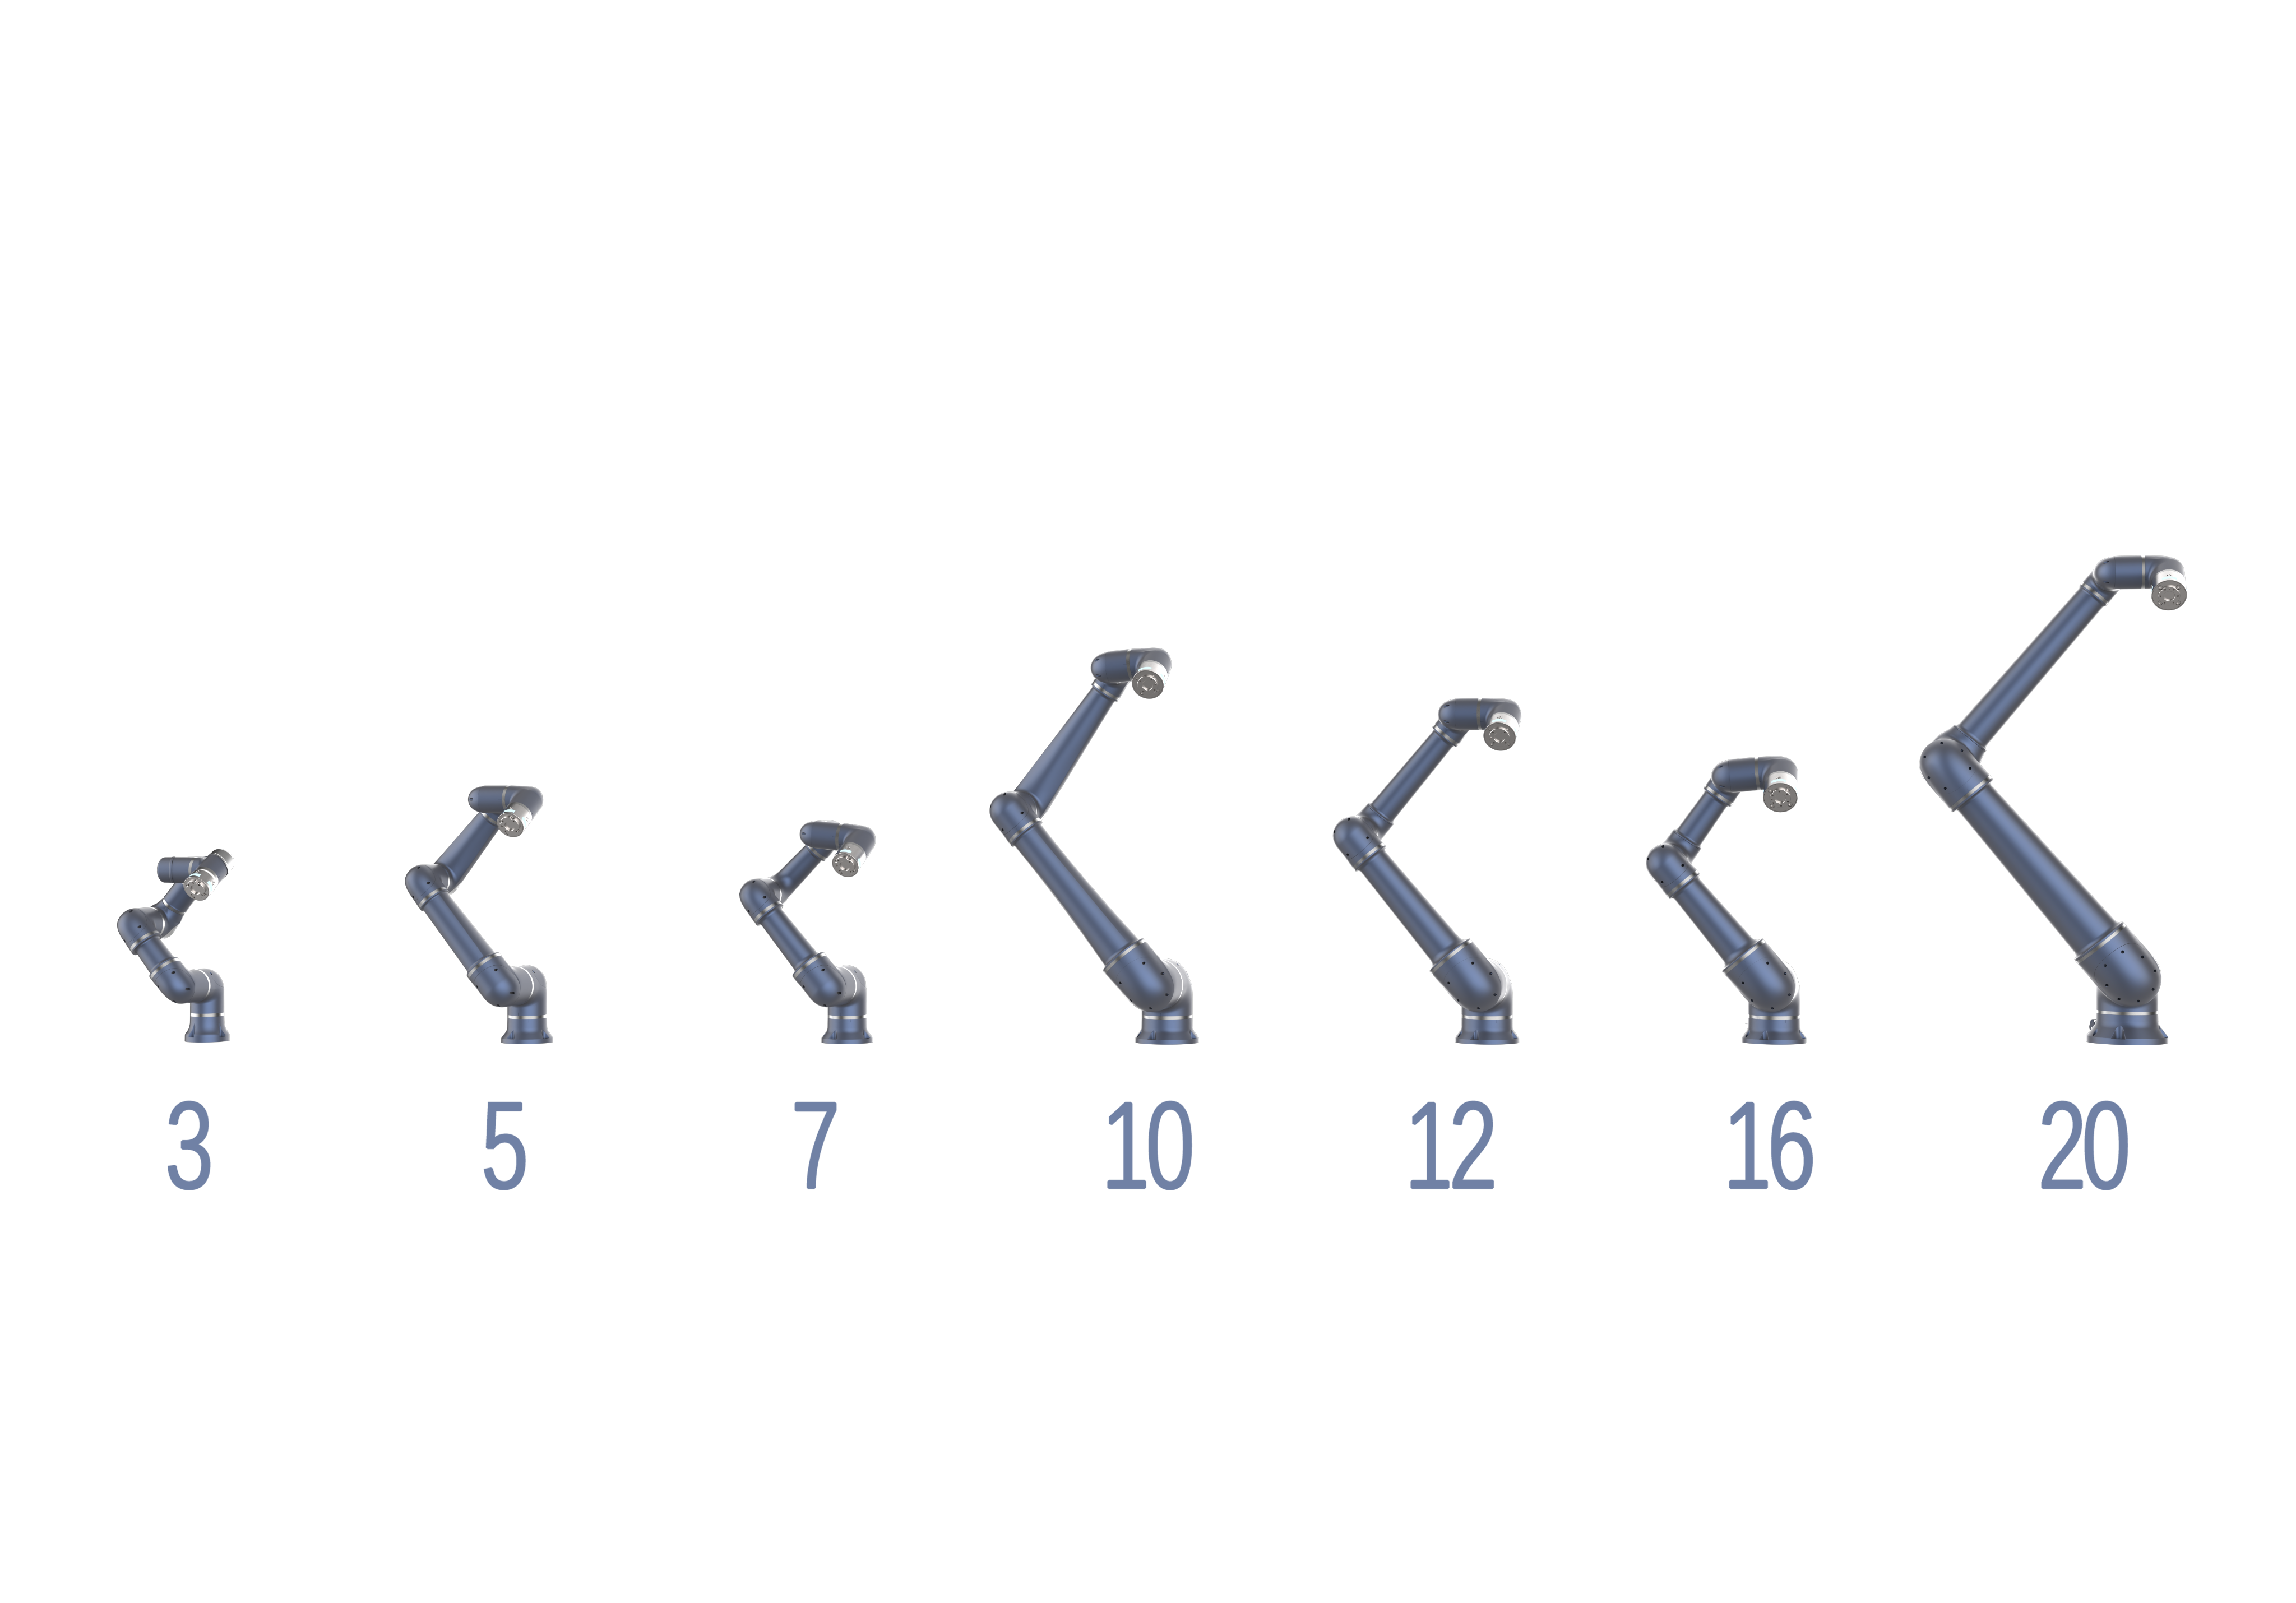
Detailed parameters

Comprehensive protection
multiple safety guaranteeComply with international safety standards (EN IS010218-1, EN IS013849-1 Pld. Cat.3), with safe torque shutoff (STO) and safe brake control (SBC) functions; Highly sensitive collision detection, effectively guaranteeing personnel safety; Full-joint brake configuration ensures that the robot will not fall down in case of abnormal power failure.

Flexible and easy to use Standardization and customization
The flexible dragging teaching function can easily realize accurate point and track teaching; Intuitive graphical programming interface combined with drag teaching, "0" basic user can quickly start (master the basic operation within 1 hour); Easy integration of visual systems to meet automation requirements in unstructured and dynamic environments.

Excellent performance
precise motion controlIt has joint speed and terminal speed comparable to traditional industrial robots, and operates efficiently; Industrial robot level accuracy; Precise robot precision calibration and compensation technology is adopted to achieve industrial robot precision;

Excellent quality
perfect quality systemGuarantee of strict production quality management system; Consistent manufacturing quality control and quality inspection process to ensure reliable product performance and quality; Kinematical calibration of the robot shall be completed before delivery to ensure absolute accuracy. Each robot shall pass 100+design type tests and 20+delivery inspections. Each robot shall pass 120 hours of continuous trouble-free operation test before delivery.
Download Materials
| FileName | Category | Format | Release Date | Operation | |
|---|---|---|---|---|---|
| No documents found. | |||||


